Platforms Robotics
AGI Hand v2
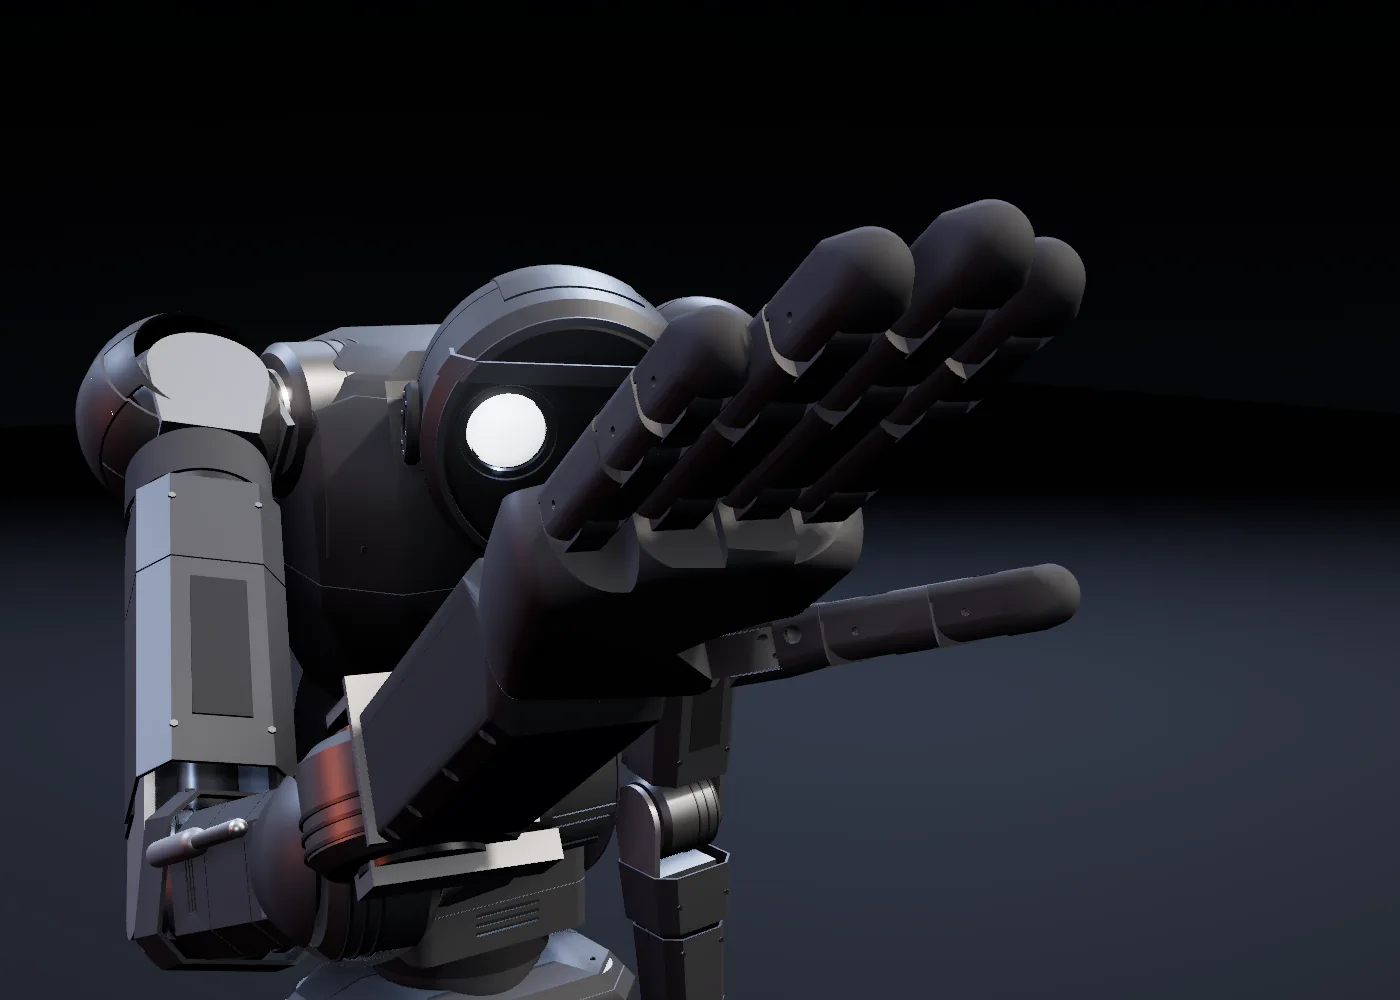
The hand of Kova K2
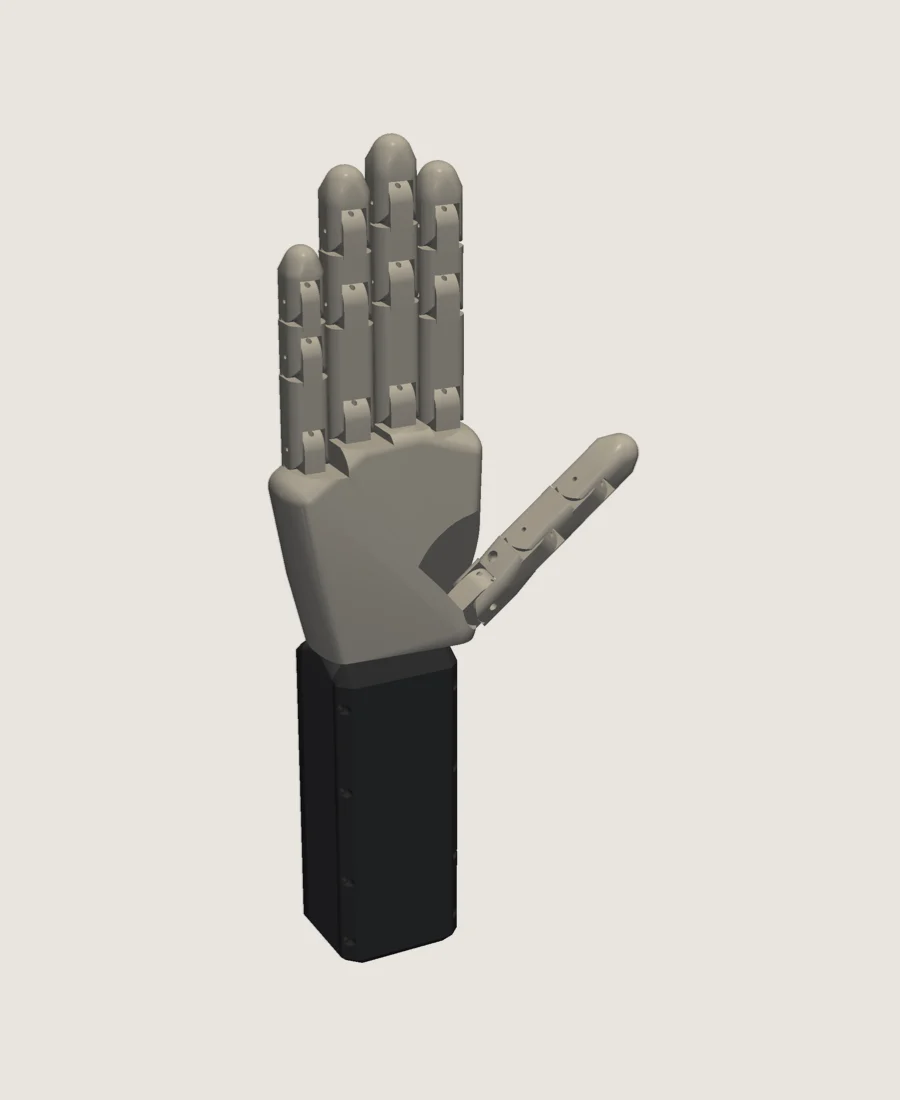
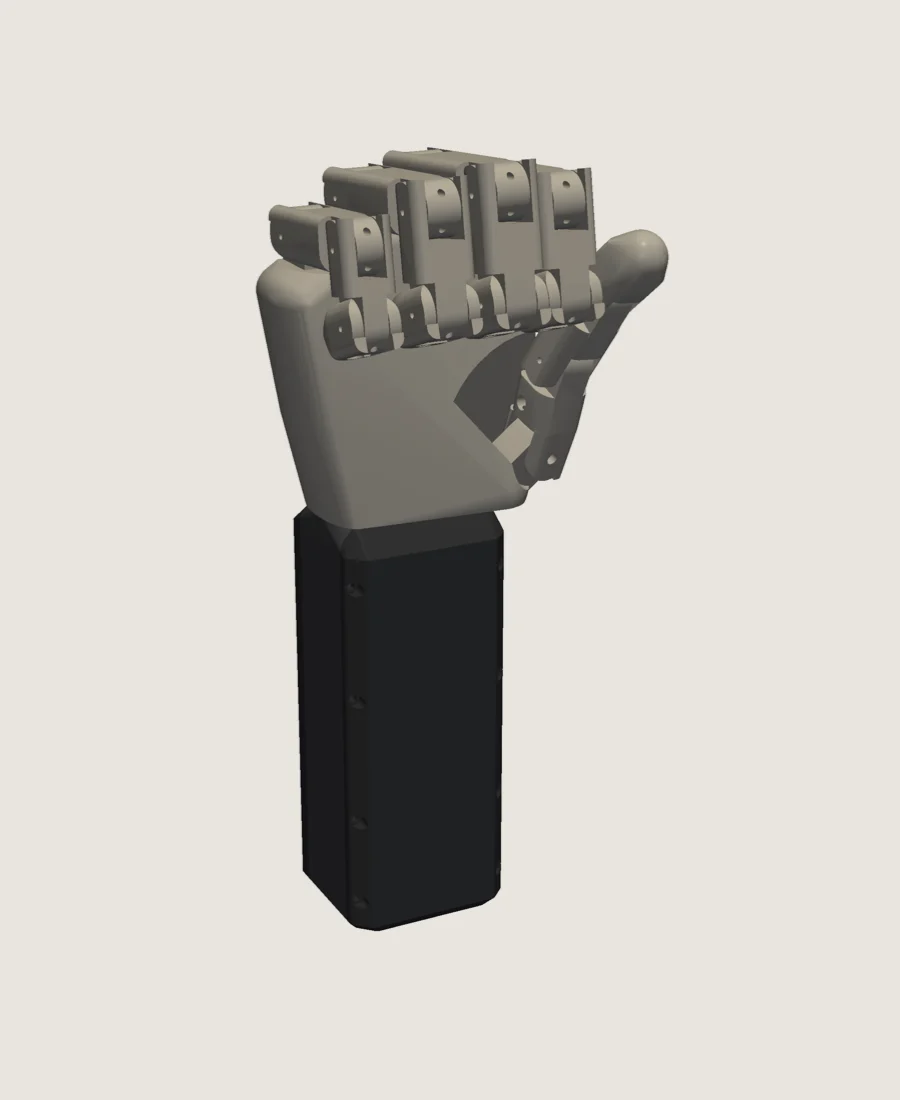
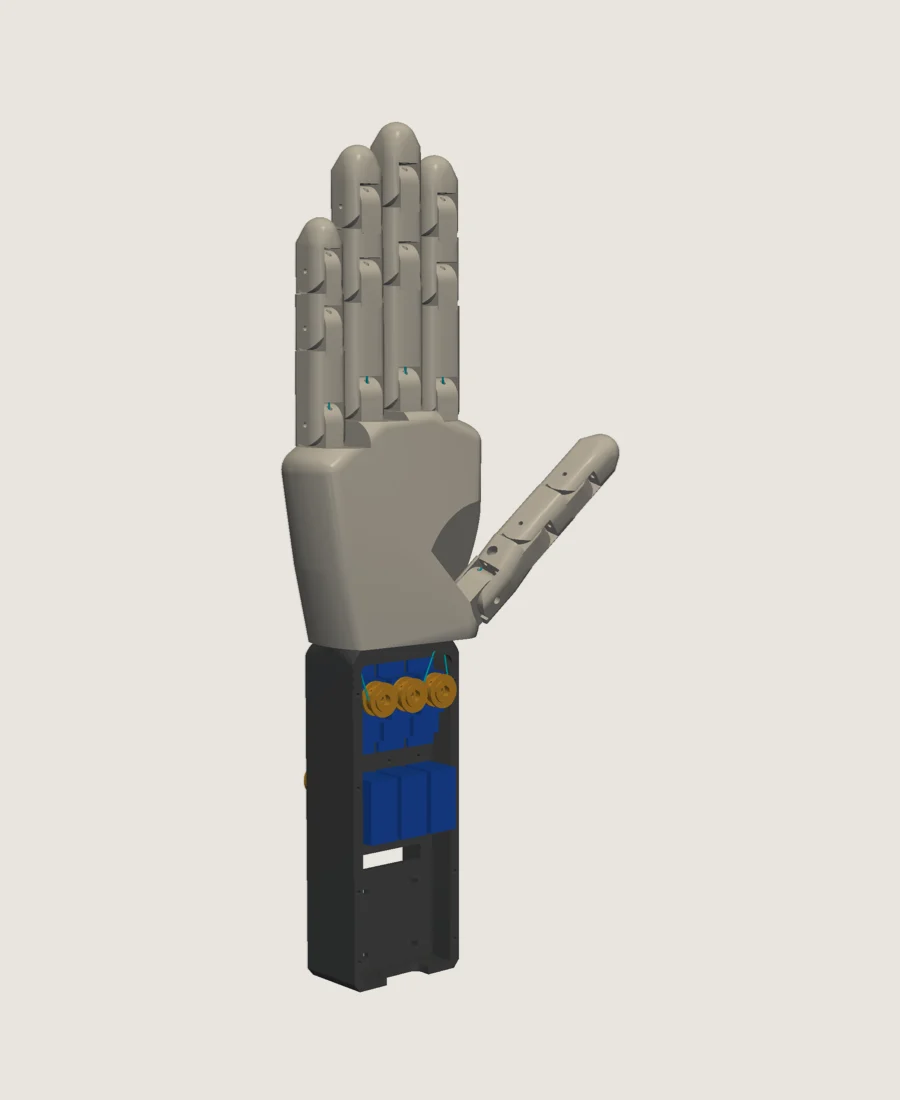
A tendon-driven robot hand. Tendons run from each finger through the wrist to six smart servos in the forearm module, the layout the 1X NEO hand uses. On Kova K2 the hand is scaled 1.23×, while the servos and spools stay real size.
Specs
- Articulations
- 15
- Independent motions
- 6
- Actuators
- 6 × Feetech SCS0009 serial bus servos, in a 50 × 46 mm wrist module
- Feedback
- Each servo reports position, load and temperature on one daisy-chained bus
- Drive
- Tendons to the palm side, elastic return on the back
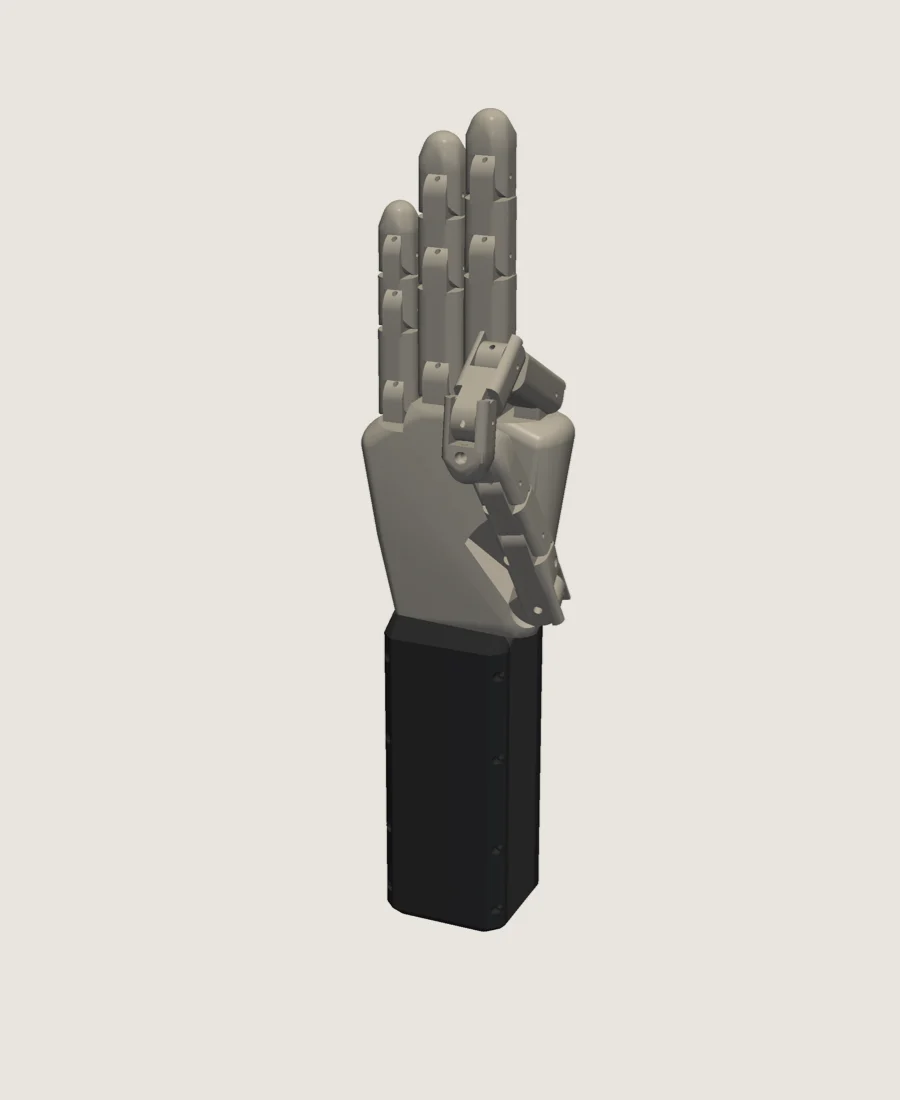
- Thumb
- Curl, plus an opposition swing to meet the fingertips
- On Kova K2
- Scaled 1.23×, dark finish; the servos and spools stay real size
Simulator
Every motion, in the browser. Curl each finger and swing the thumb into opposition, one slider per servo.
Try the simulatorOn Kova K2
Scaled 1.23× for a 2.16 m robot.
On K2 the hand's shells are scaled 1.23× and finished dark, so its length is about 10.8 % of K2's height. Because the servos stay the same, bigger fingers mean longer levers and a lighter grip than the full-size hand.